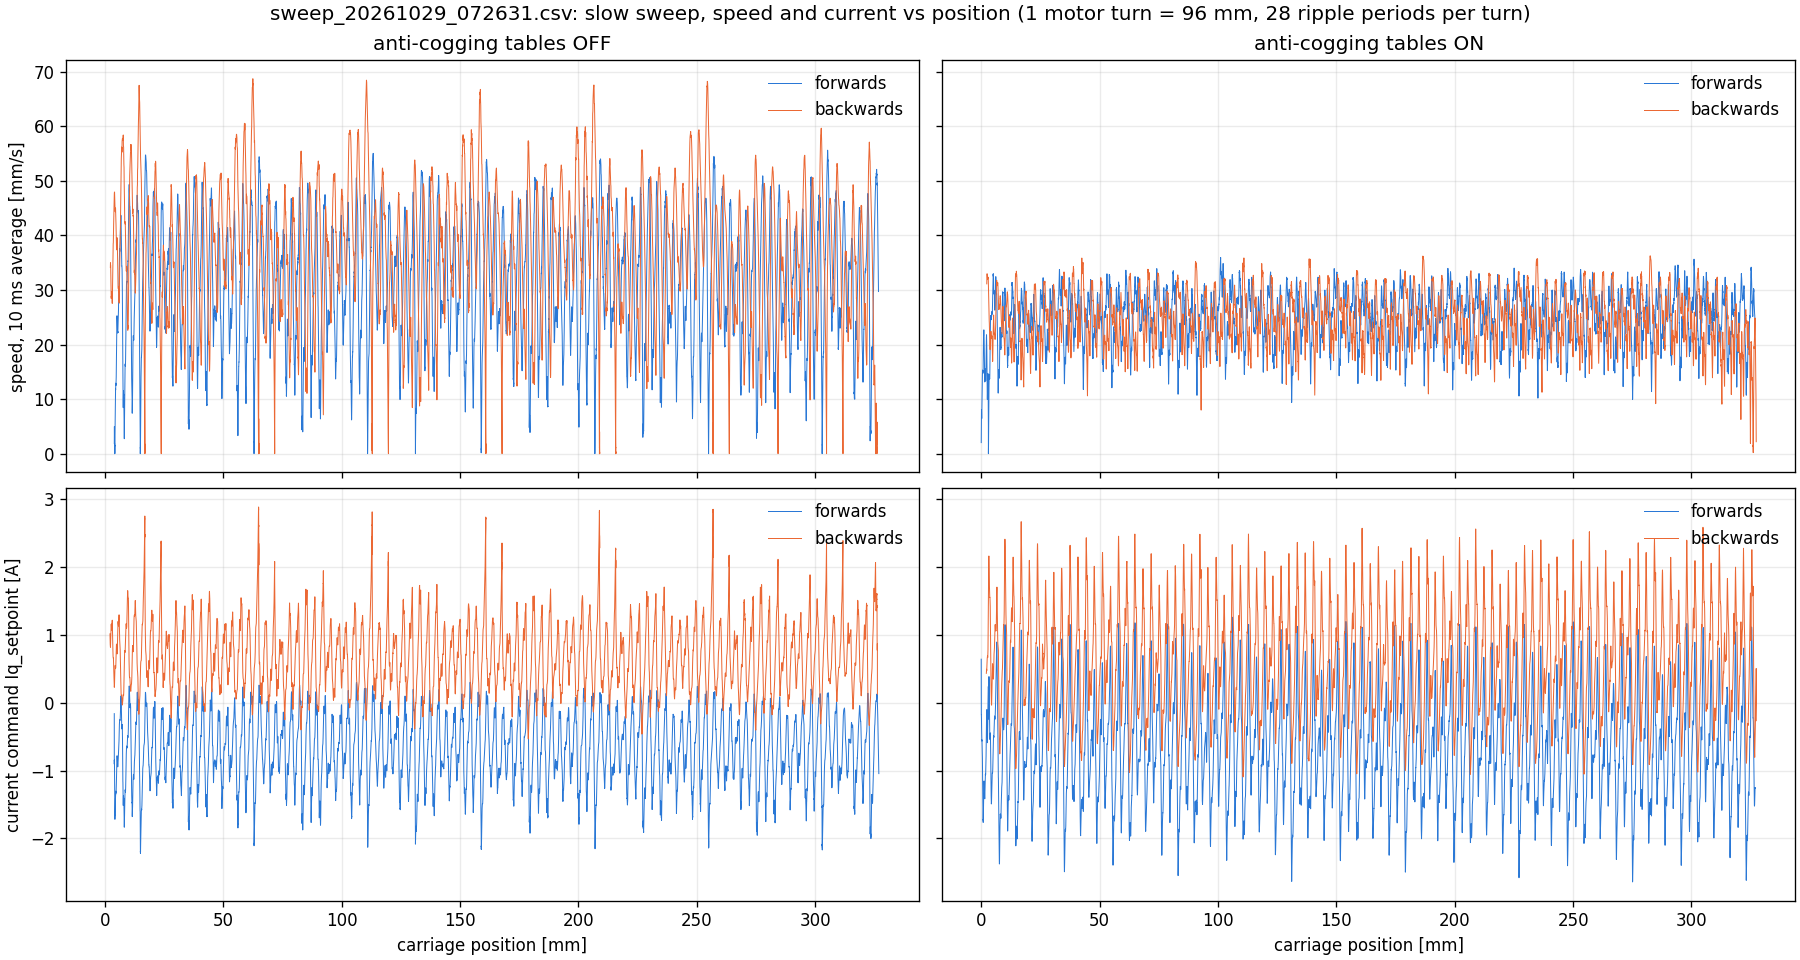
Cogging
The cogging with this linear rail is extremely severe. the motor jerks is extremely jerky in a start-stop fashion at low speeds, it practically comes to a stop then leaps forward again. It is however being run with an odrive, which is of course open source. So I asked claude to build a table of motor currents as a function of position so that it could invert this cogging in the driven motor currents to get a smooth velocity, which resulted in this: